

Tote-Handling Robots
Overview
In tote-handling applications, 3D cameras provide reliable 3D perception. For regularly arranged totes and storage locations, they identify tote pose and storage-location coordinates for high-accuracy, high-throughput storage and retrieval. In dense storage areas, point-cloud data reconstructs tote geometry and the surrounding environment to guide pick-and-place positioning and avoid collisions, supporting efficient tote turnover across warehouse workflows.
Key Challenges
-

 Varied tote materials, surface imperfections and reflections cause recognition errors
-
 Dense storage locations and stacked totes create severe occlusion
-
 Complex warehouse lighting and dust reduce pose estimation accuracy
Key Advantages
-


Captures 3D point clouds of storage locations for accurate tote storage and retrieval
-

Recognizes stacked-tote geometry to plan efficient pick-and-place paths
-

Delivers stable operation in dense warehouse areas, even under stray light and dusty conditions
Recommended cameras
-
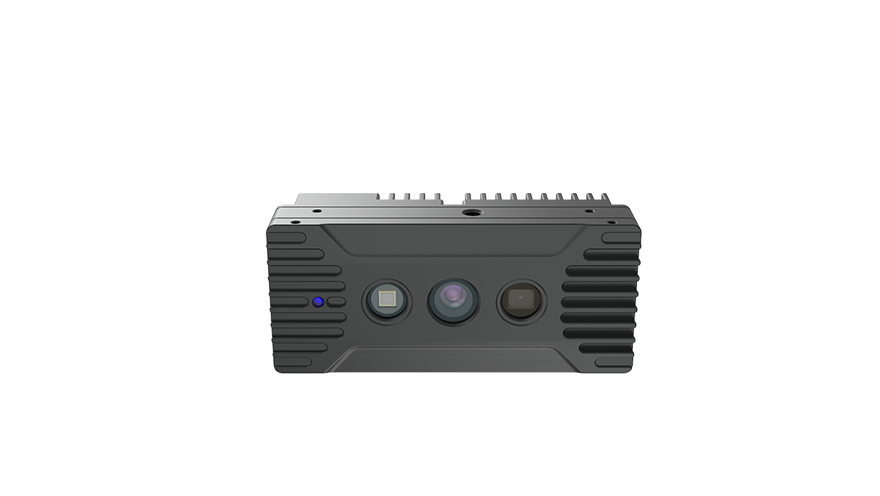
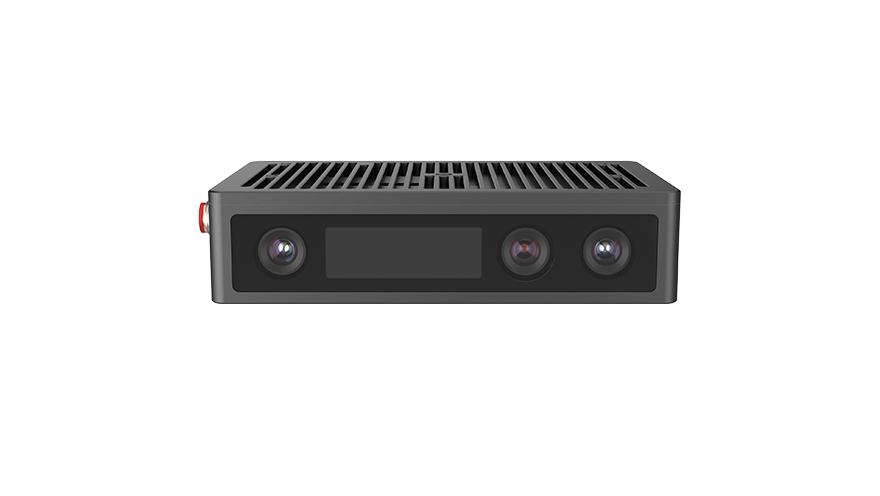
 FM855-E1
Utilising proprietary active stereo vision technology, it offers richer depth-of-field detail and greater environmental adaptability, supporting intelligent upgrades across multiple sectors including robotics, industry and commerce.
Learn More -
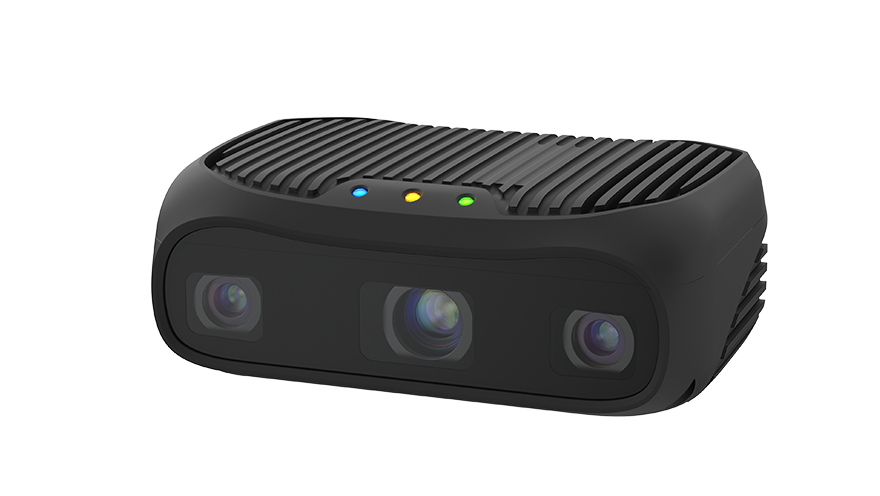
 GM465-E1
A cost-effective 3D industrial camera with a 100 Mbps Ethernet interface that combines industrial-grade accuracy with an affordable price. It supports both high-speed and high-precision modes and is suitable for a wide range of general-purpose applications across various fields.
Learn More -
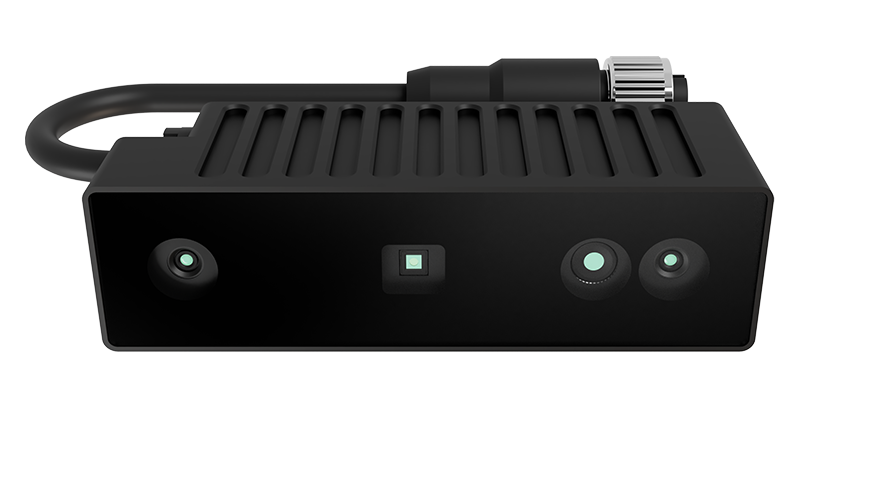
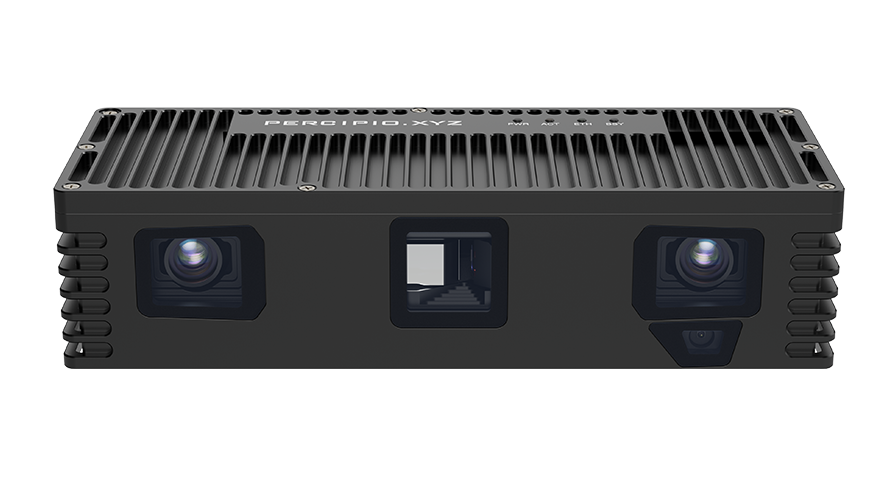
 FM854-E1
Utilising proprietary active stereo vision technology, it provides more comprehensive depth-of-field information and greater adaptability to the environment, helping to drive intelligent solutions across a wide range of sectors, including robotics and industry.
Learn More