

Mobile Manipulators
Overview
In mobile manipulator applications, 3D cameras provide reliable 3D perception. At structured workstations, they identify workpiece position and pose for high-accuracy, high-throughput pick, place, and assembly operations. Across flexible production lines, point-cloud data reconstructs parts, equipment, and nearby obstacles, enabling the robot to identify task locations, avoid collisions, and plan motion paths.
Key Challenges
-

 Varied workpiece and fixture materials, surface reflections and machining oil degrade vision recognition accuracy
-
 Compact workstations create occlusion, with highly variable workpiece poses
-
 Dust and variable factory lighting reduce perception reliability
Key Advantages
-


Captures complete production-line 3D point clouds for accurate workpiece and workstation localization
-

Recognizes workpiece pose to support flexible motion path planning
-

Delivers stable operation despite dust and variable factory lighting conditions
Recommended cameras
-
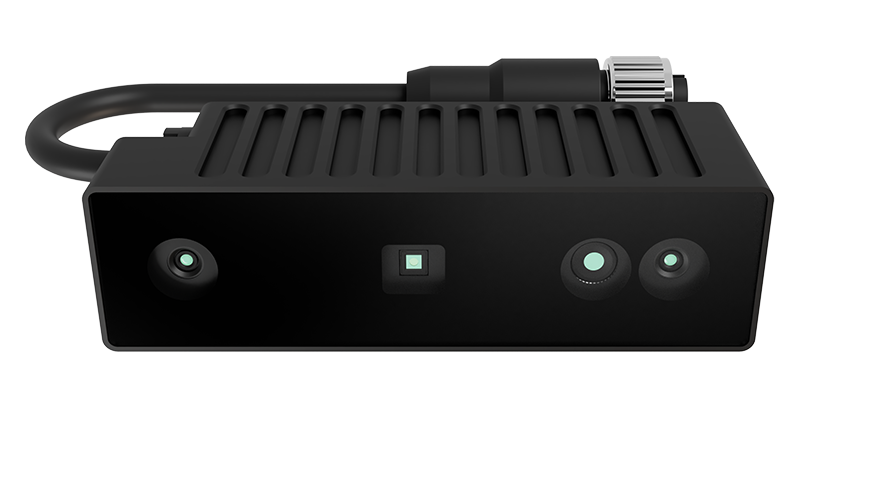
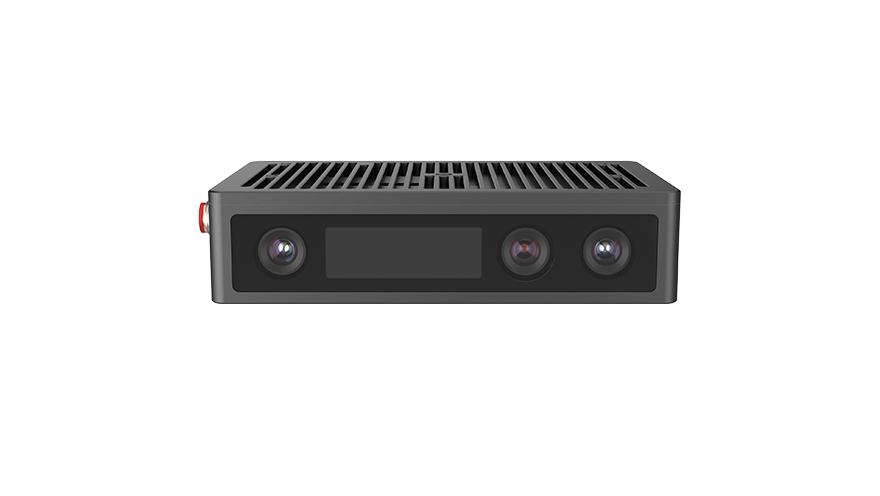
 USD01
A compact striped structured light 3D camera that delivers precise close-range identification and positioning. Featuring a compact design and high-precision point cloud imaging, it supports HDR and is suitable for high-precision guidance applications such as loading/unloading and positioning/assembly.
Learn More -
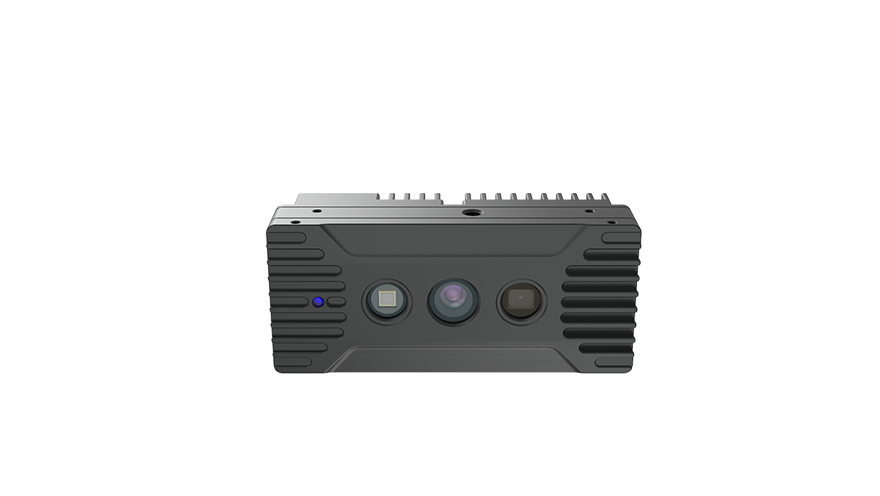
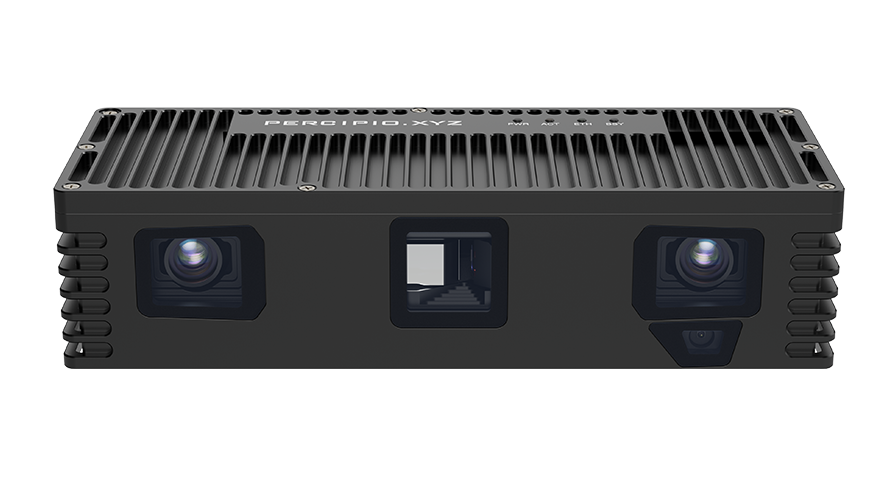
 PS800
Utilizing proprietary active stereo vision technology and equipped with a built-in embedded computer vision processor, it accurately captures 3D data to enable high-precision measurement of small, static objects, making it suitable for applications such as recognition, classification, and localization
Learn More -
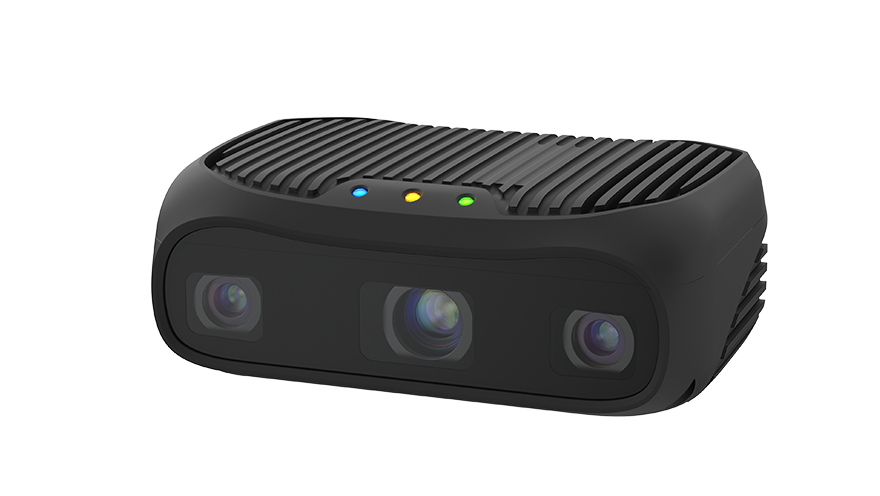
 GM465-E1
A cost-effective 3D industrial camera with a 100Mbps Ethernet interface, combining industrial-grade precision with an affordable price. It supports both high-speed and high-precision modes, making it suitable for a wide range of general-purpose applications.
Learn More