

Ordered & Random Bin Picking
Overview
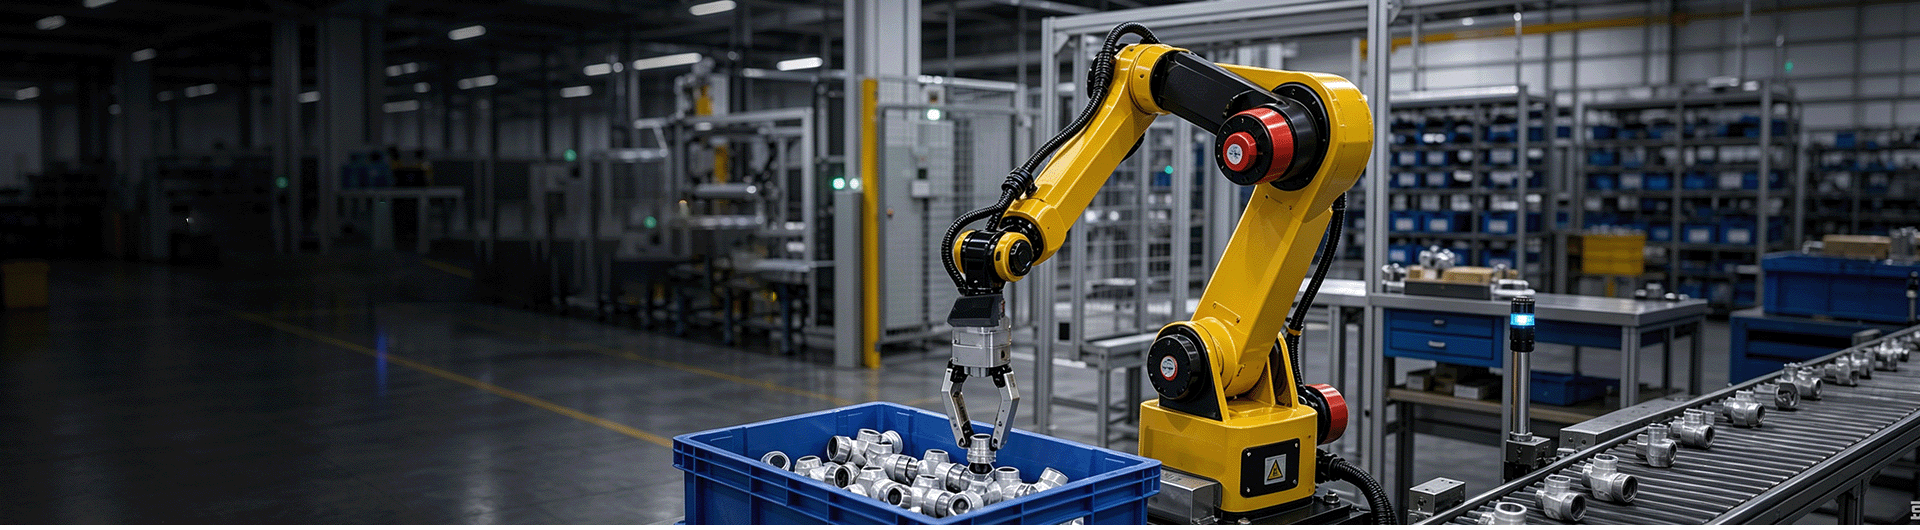
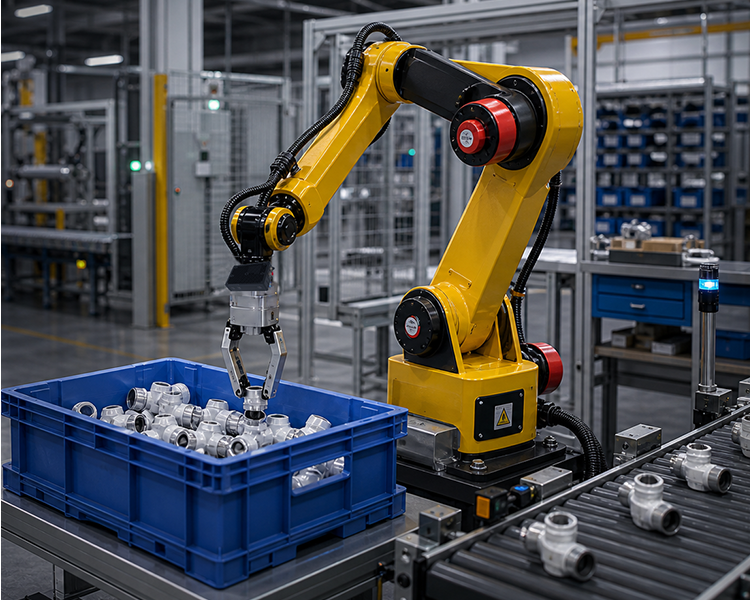
In automated picking applications, 3D cameras provide robots with reliable 3D perception. For ordered picking, the cameras can quickly identify neatly arranged objects, enabling high-precision, high-throughput target picking.
For unordered picking, the cameras use point-cloud data to accurately determine the spatial configuration and orientation of stacked, scattered, or mixed objects, allowing the robot to determine the picking pose, avoid collisions, and plan the optimal picking path.
Key Challenges
-

 Most surfaces are metallic, reflective, or dark in colour, and materials are highly complex
-
 The orientation of tightly packed or randomly piled objects is unpredictable, with severe occlusion
-
 Dust, oil residue, and fluctuating ambient light make stable recognition in industrial settings particularly challenging
Key Advantages
-


High-quality, complete point-cloud imaging supports high-precision 3D measurement and localisation
-

Intelligently identify workpiece orientation and position to assist robots in planning optimal picking paths
-

Robust against ambient-light interference and compliant with IP-rated protection standards
Recommended Cameras
-
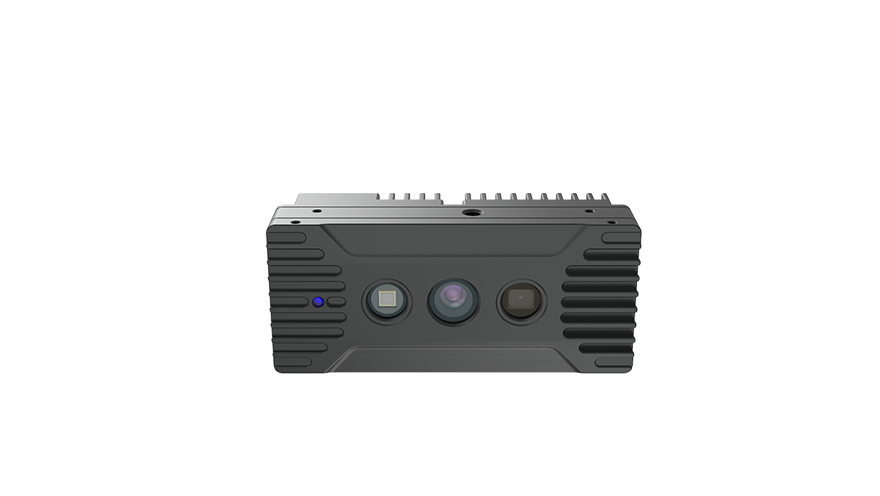
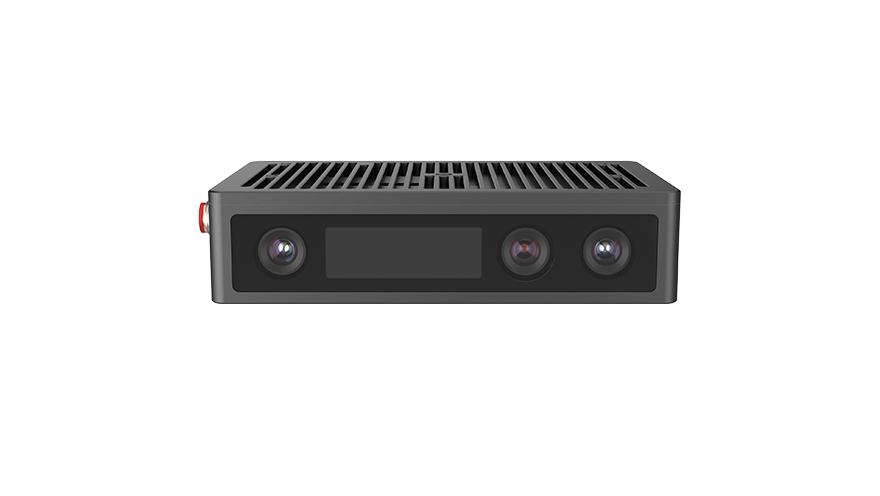
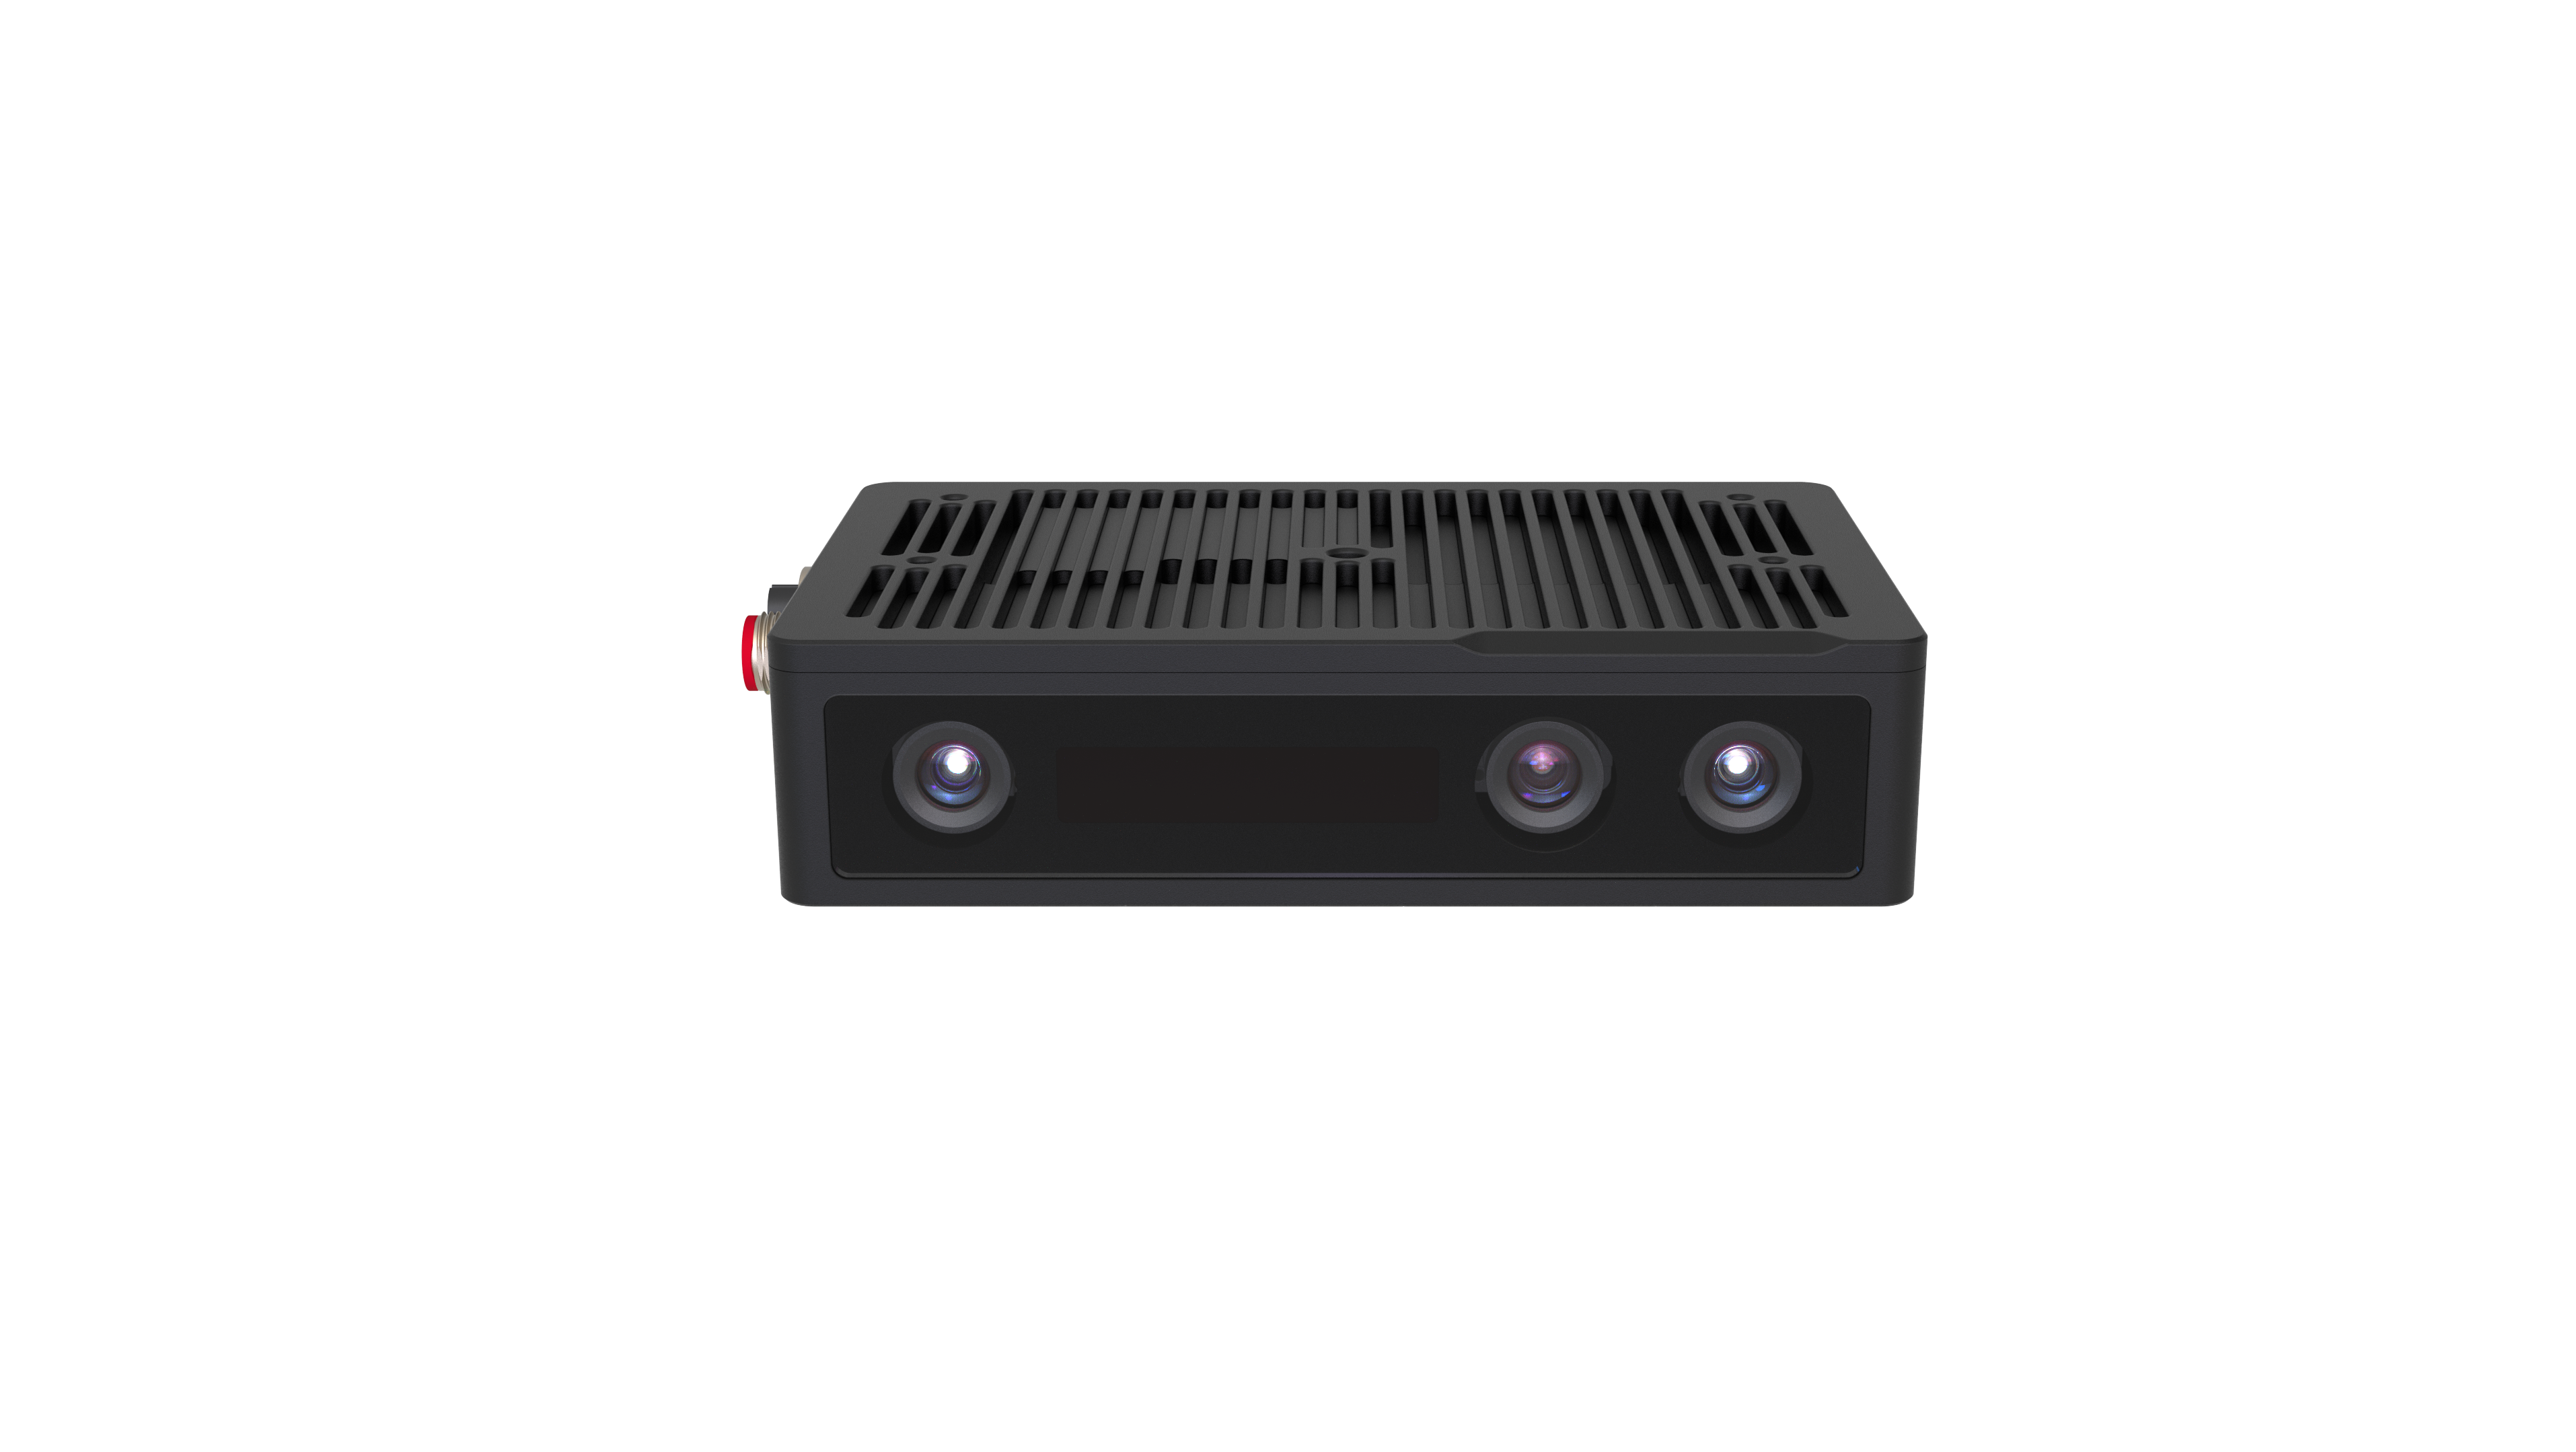 FM855-E1
Utilizing proprietary active stereo vision technology, it offers richer depth-of-field details and greater environmental adaptability, driving intelligent upgrades across multiple sectors including robotics, industry, and commerce.
Learn More -
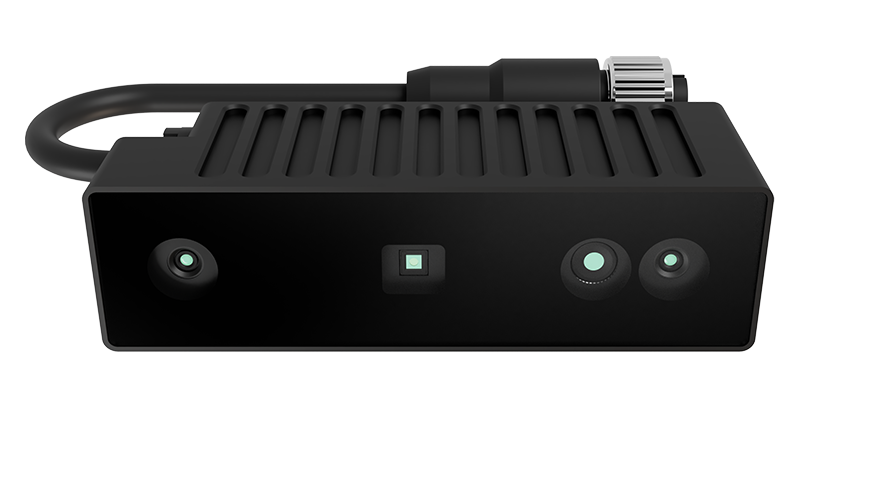
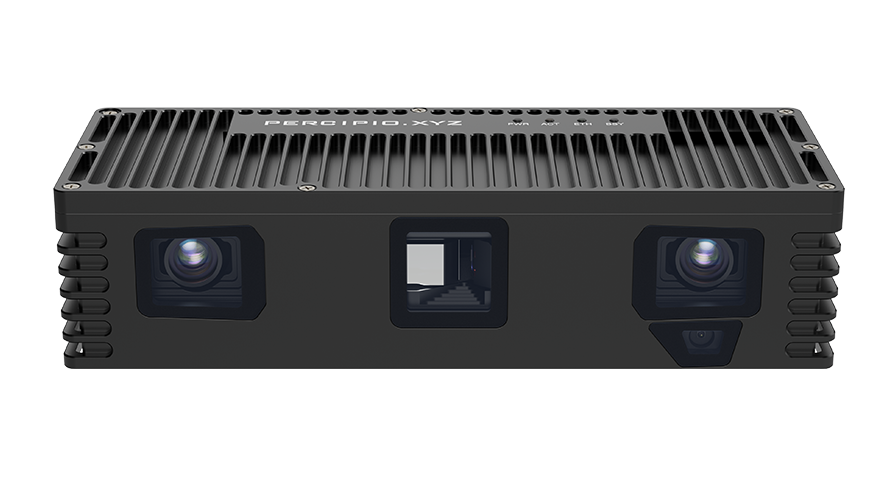
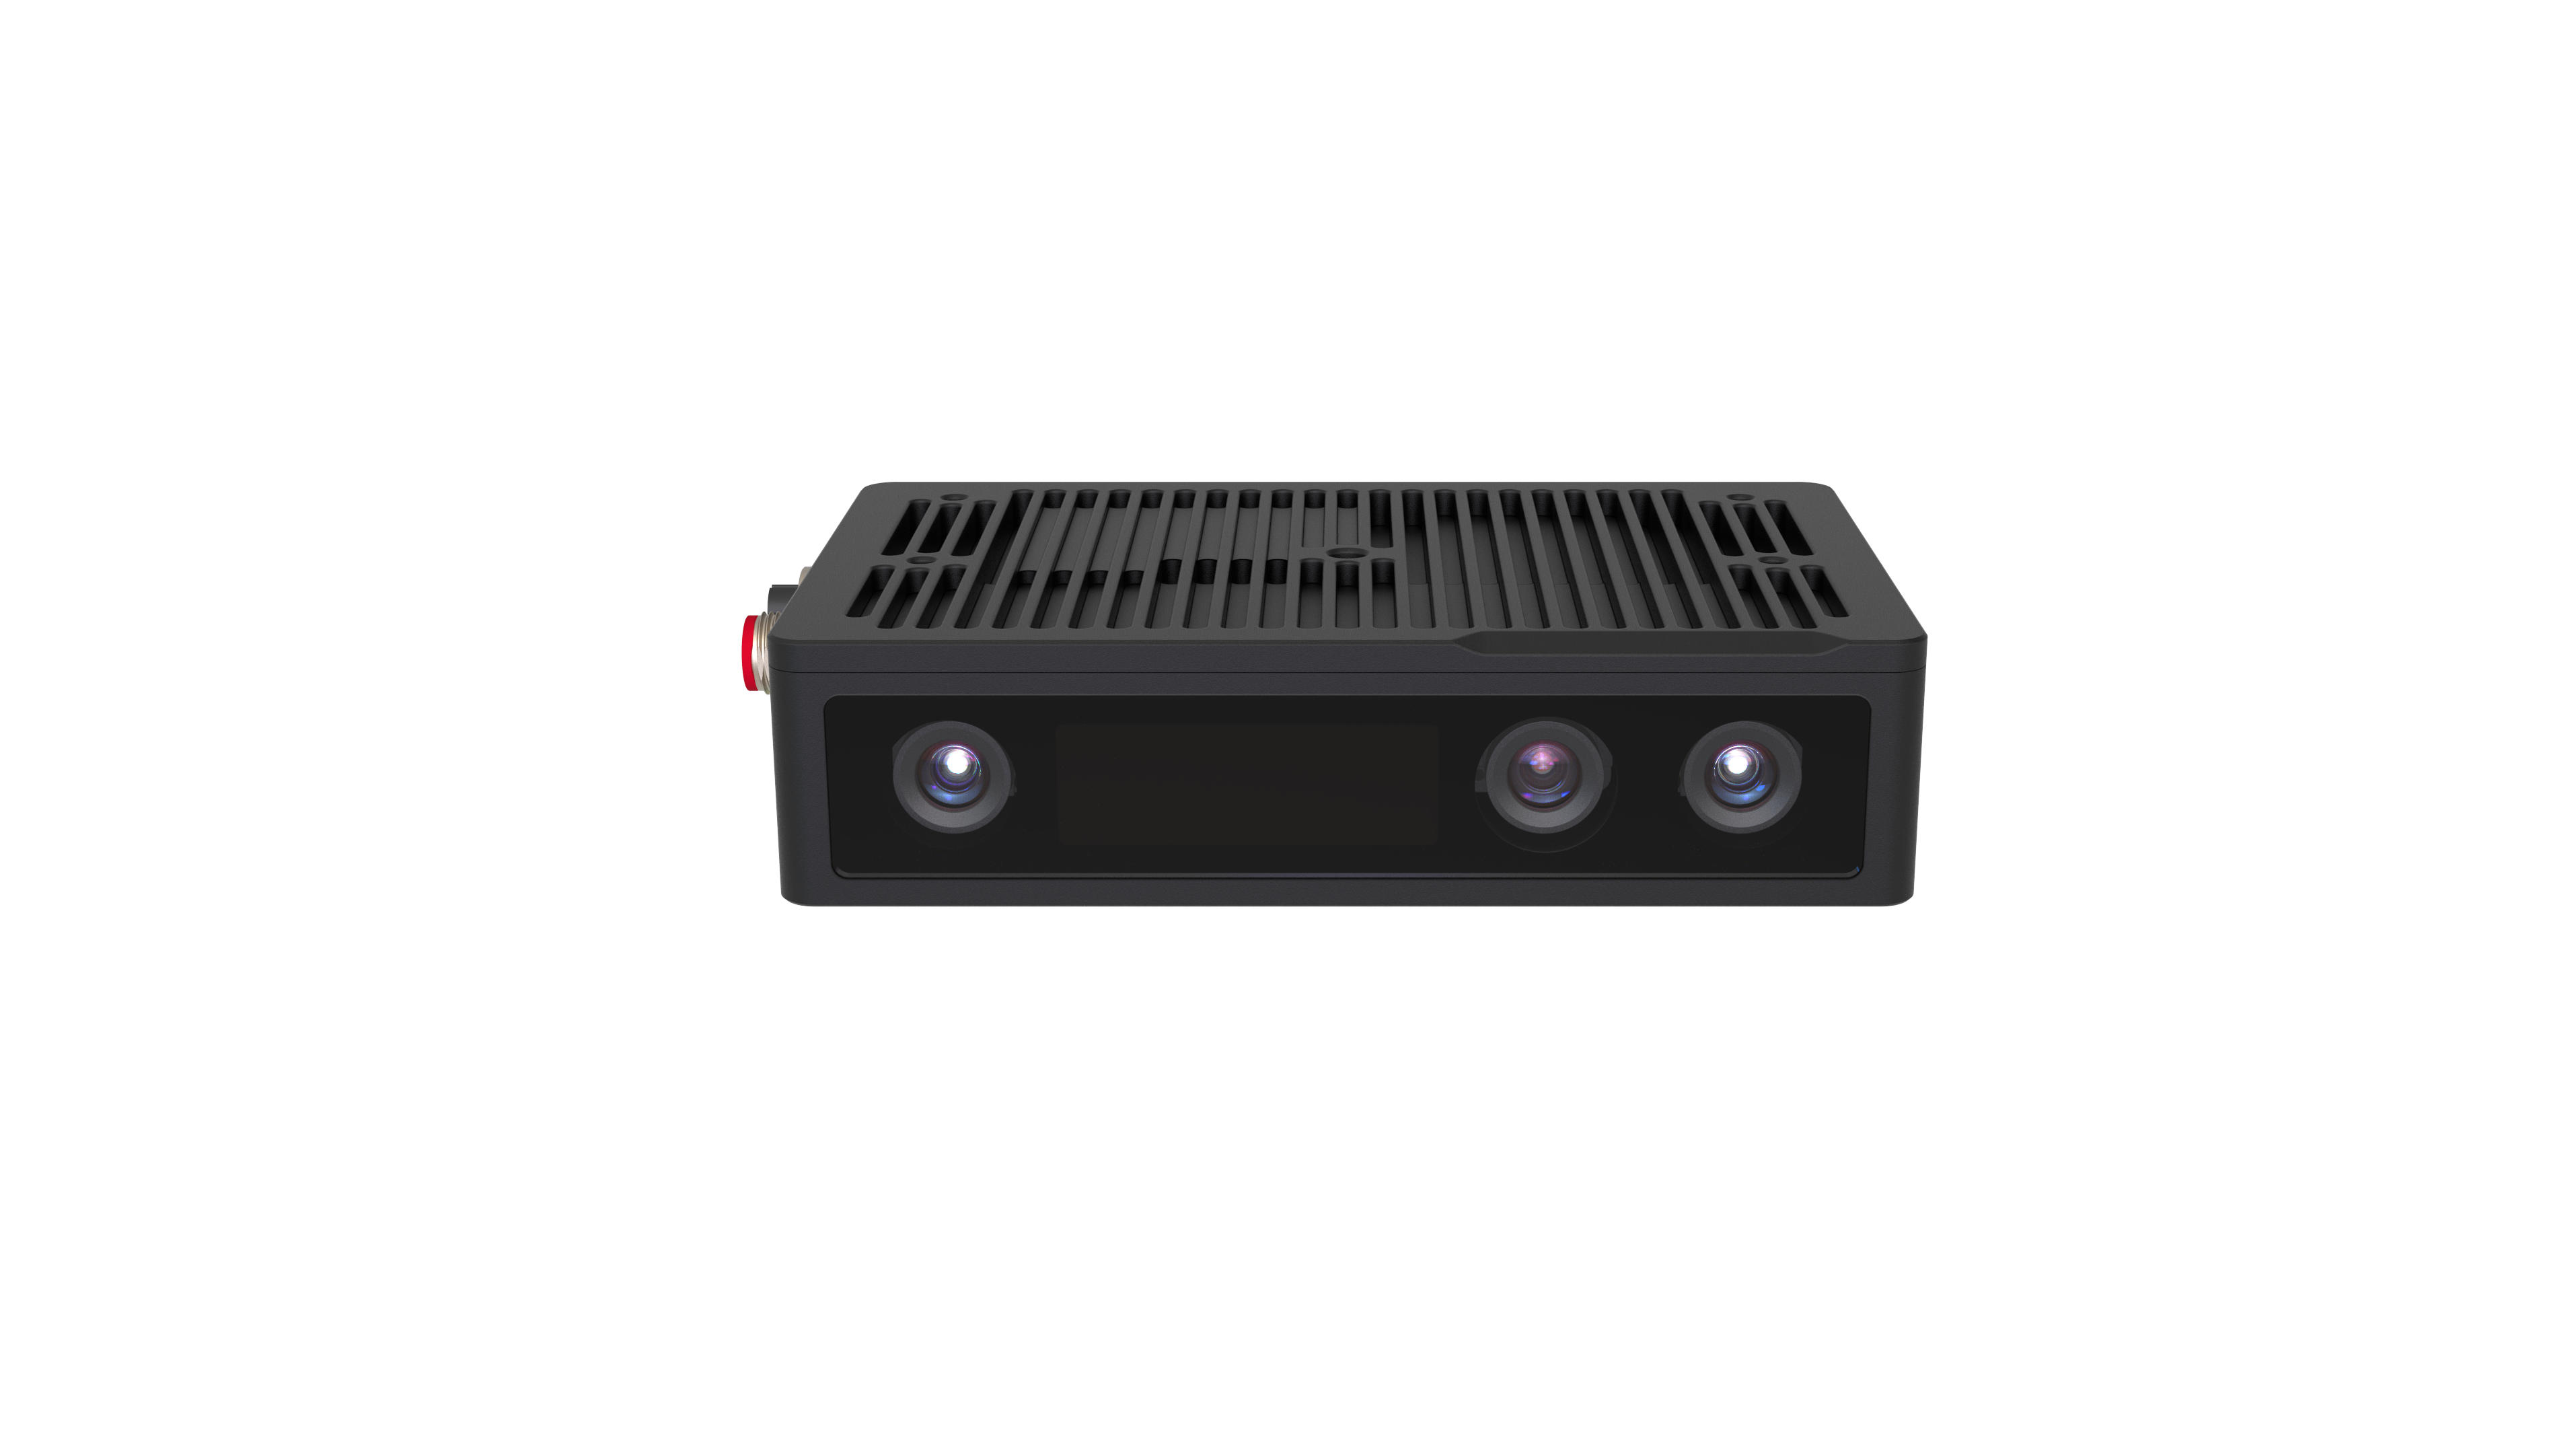 FM815-IX-E1
Equipped with proprietary active stereo vision technology, it offers superior depth-of-field detail and greater environmental adaptability compared to traditional stereo systems, enabling intelligent applications across multiple fields.
Learn More -
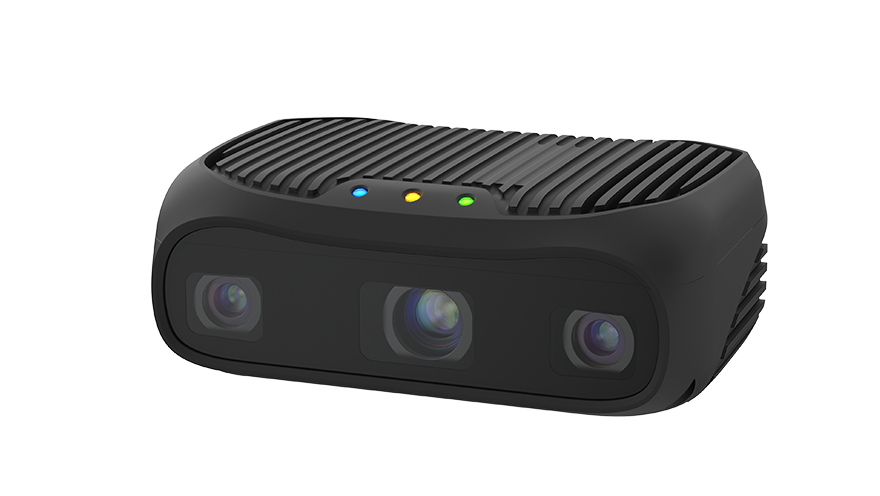
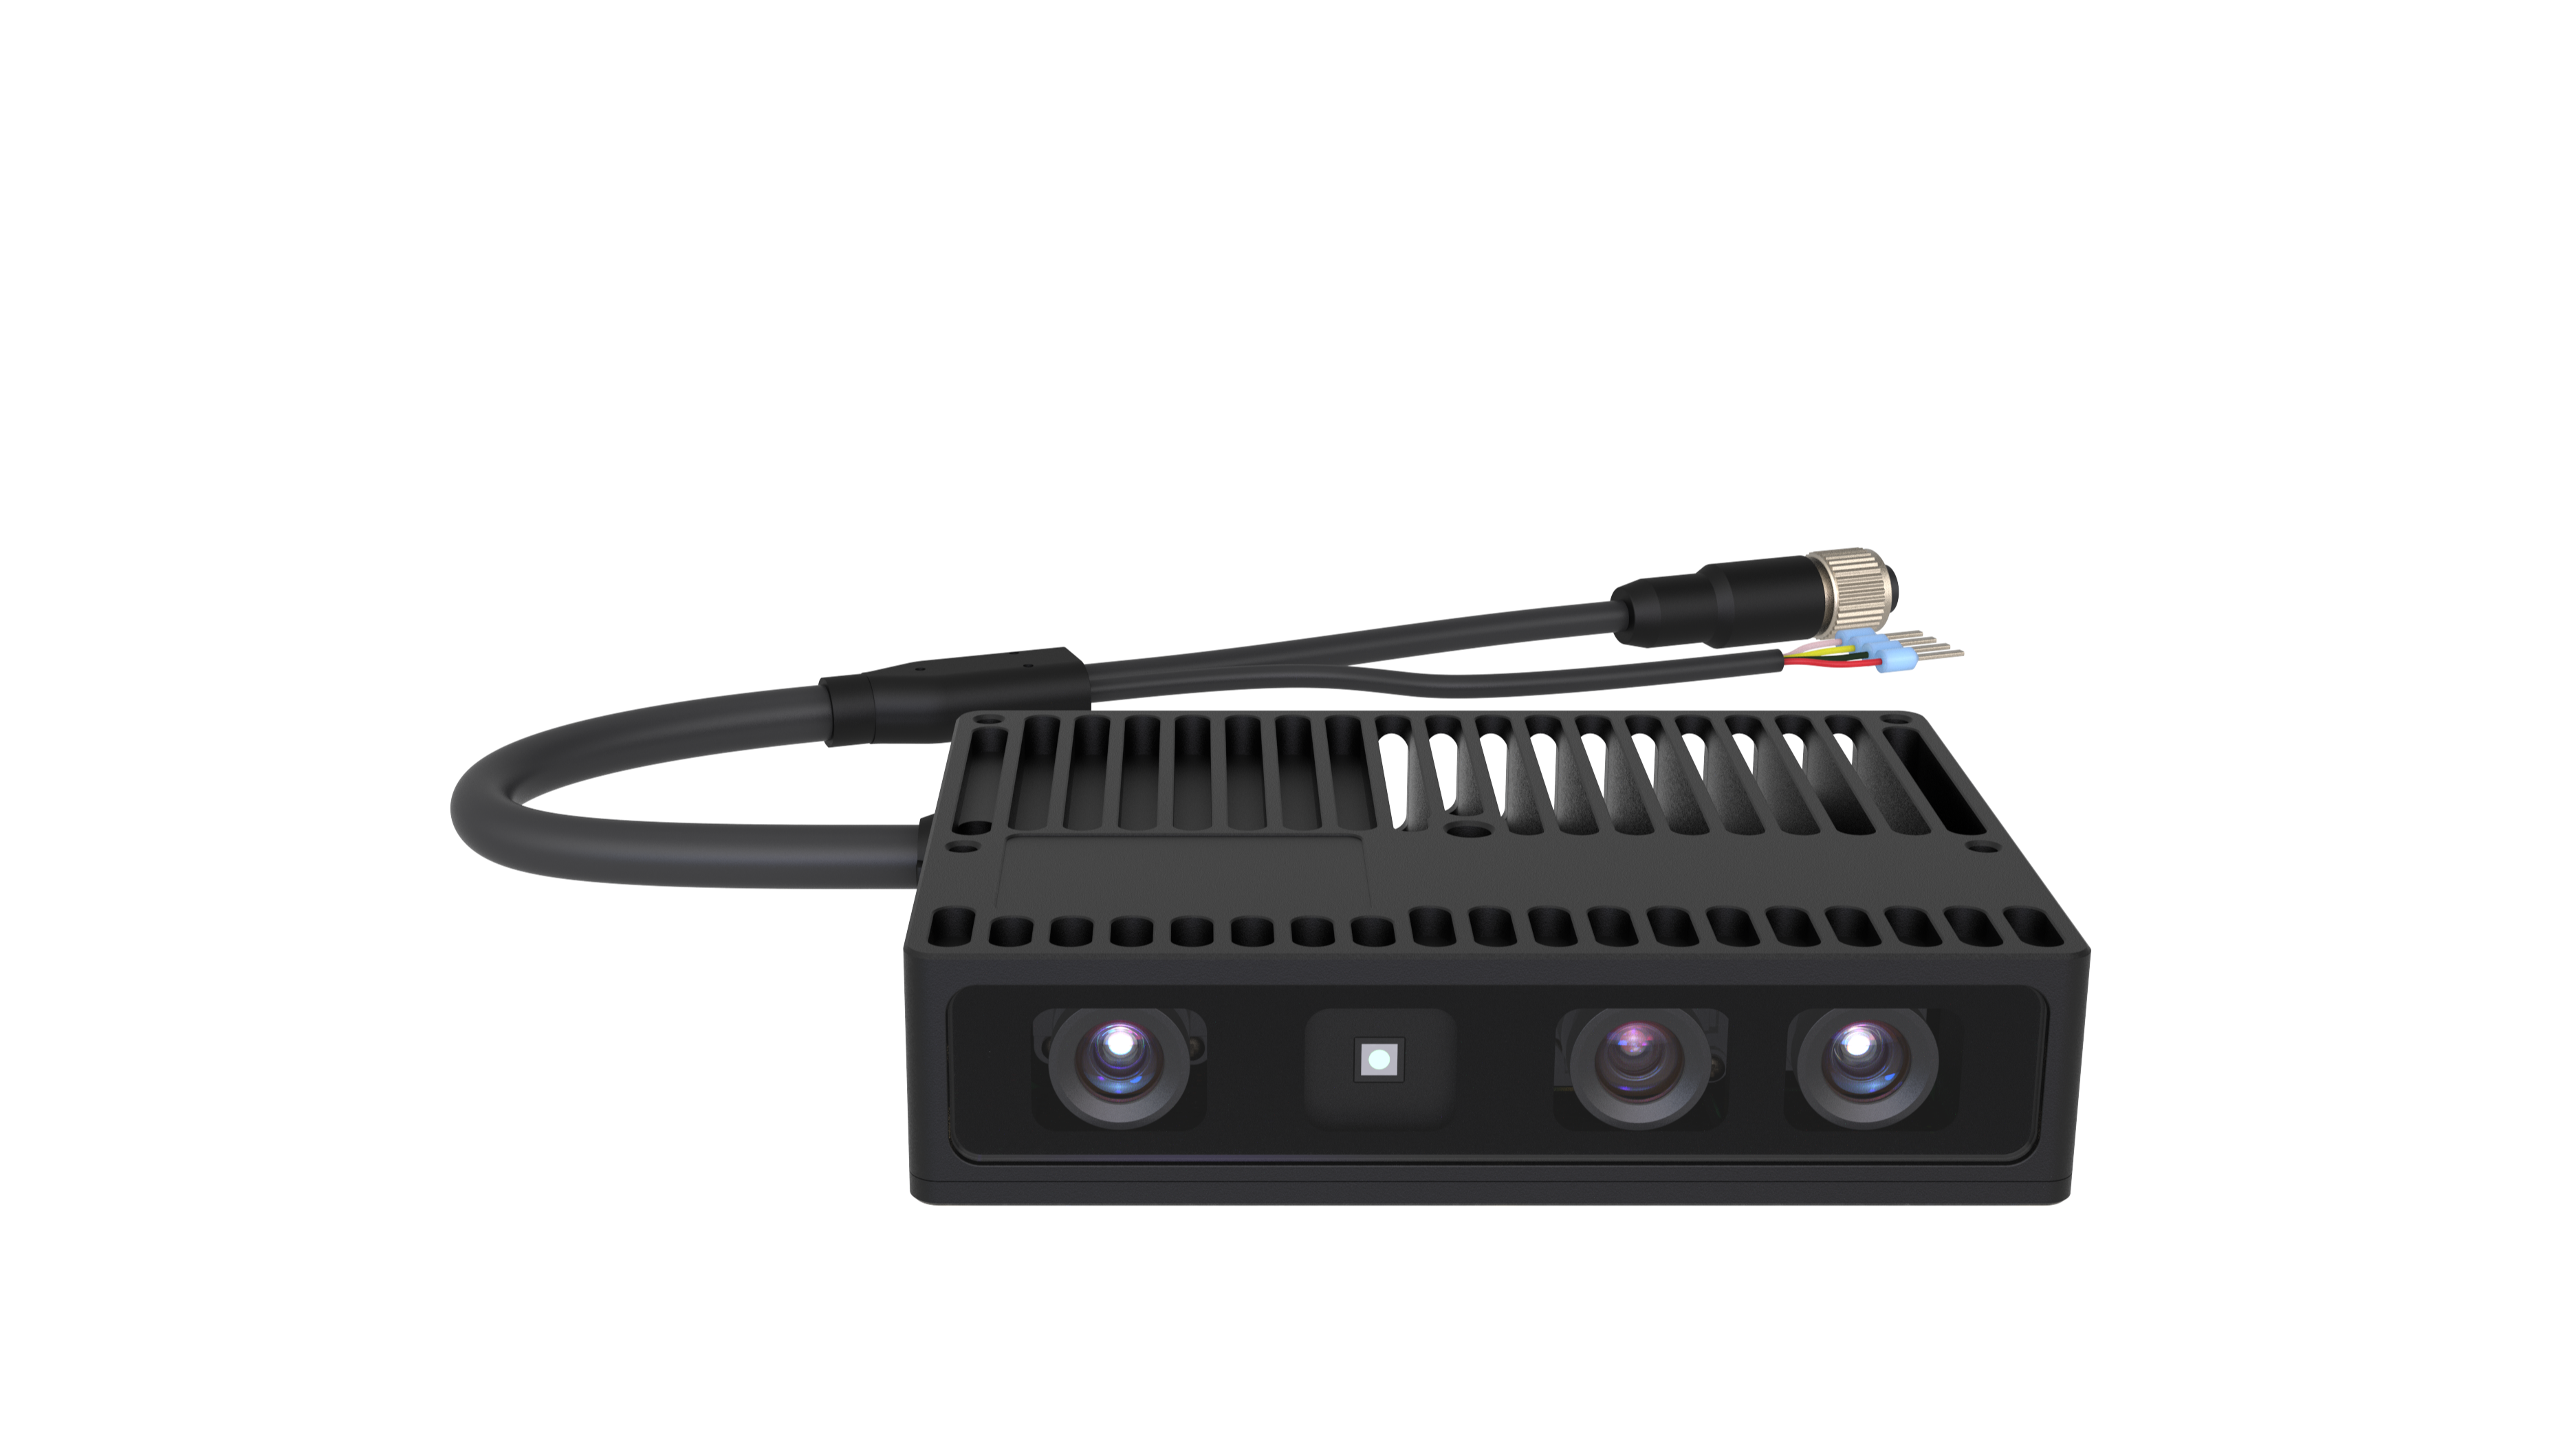 FM854-E1
Utilizing proprietary active stereo vision technology, it provides more comprehensive depth-of-field information and stronger environmental adaptability, helping to advance intelligent solutions across various fields such as robotics and industry.
Learn More