

Embodied AI
Overview
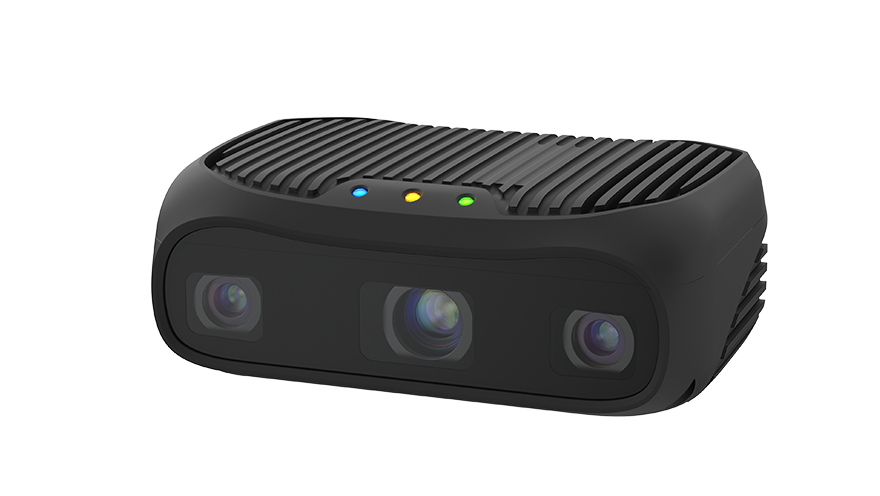
In embodied AI applications, 3D cameras provide robust 3D environmental perception for humanoid and general-purpose robots. In structured environments, cameras rapidly identify target objects and task locations to enable precise, efficient autonomous operation. In dynamic unstructured settings, real-time point cloud reconstruction captures surrounding scenes and object geometry, helping robots assess environmental conditions, avoid hazards, and plan task paths for safe, natural human-robot interaction.
Key Challenges
-

 Diverse object materials, surface reflections, and soft-object deformation cause recognition errors
-
 Highly dynamic scenes feature occluded objects with unpredictable poses
-
 Frequent lighting and clutter interference degrade perception accuracy in complex environments
Key Advantages
-


High-precision full-frame 3D point cloud reconstruction enables accurate localization of environments and targets
-

Real-time dynamic object geometry perception supports adaptive flexible interaction path planning
-

Environmental clutter for reliable autonomous operation across diverse scenarios
Recommended cameras
-
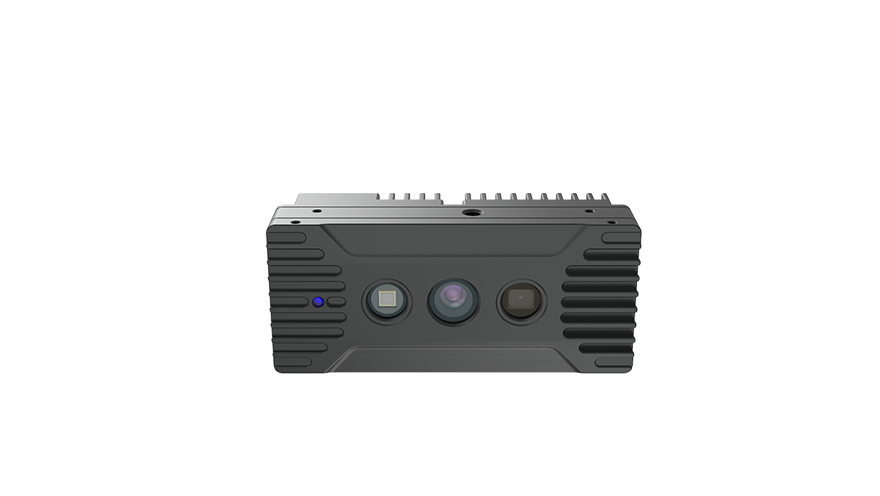
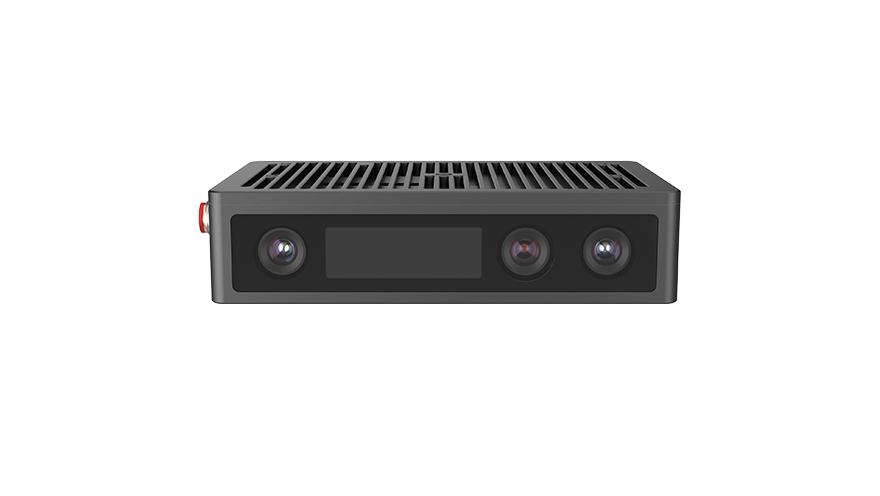
 GM461-E1
A cost-effective 3D industrial camera with a 100Mbps Ethernet interface, combining industrial-grade reliability with consumer-grade pricing. Highly versatile, it is widely used across various sectors including industry, logistics and robotics.
Learn More -
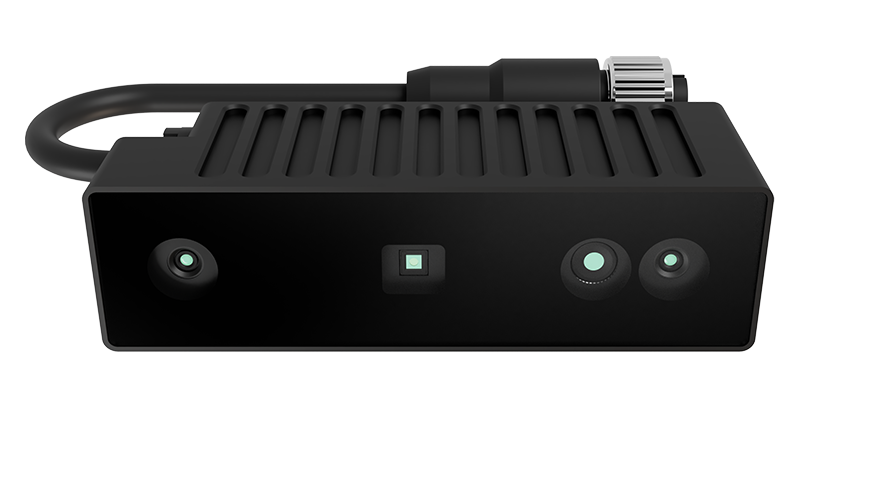
 GM463-E1
A cost-effective 3D industrial camera featuring a 100Mbps Ethernet interface and a wide field of view. Offering industrial-grade stability at an affordable price, it is widely suitable for a variety of applications, including industrial, logistics and robotics.
Learn More -
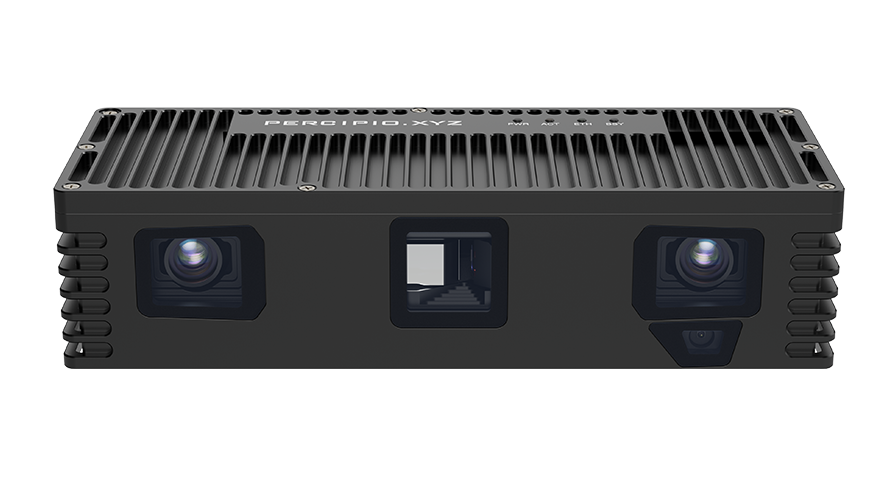
 GM465-E1
A cost-effective 3D industrial camera with a 100Mbps Ethernet interface, combining industrial-grade precision with an affordable price. It supports both high-speed and high-precision modes, making it suitable for a wide range of general-purpose applications.
Learn More