

Machine Tending
Overview
In machine-tending applications, 3D cameras provide robots with accurate 3D perception. At structured workstations, they locate the 3D coordinates and pose of workpieces to guide fast, accurate pick-and-place operations.
In randomly filled bins, point-cloud data identifies stacked-workpiece geometry and position, helping robots avoid occlusion, select grasp points, and carry out flexible automated loading and unloading.
Key Challenges
-

 Diverse materials, including reflective and dark light-absorbing surfaces, challenge vision
-
 Randomly stacked parts in bins create severe occlusion and unpredictable poses
-
 Dust and changing ambient light affect recognition stability
Key Advantages
-


Capture complete 3D workpiece information for accurate localisation and pose recognition
-

Analyze randomly stacked parts to guide flexible robotic loading and unloading
-

Robust operation in dusty workshops and changing ambient light
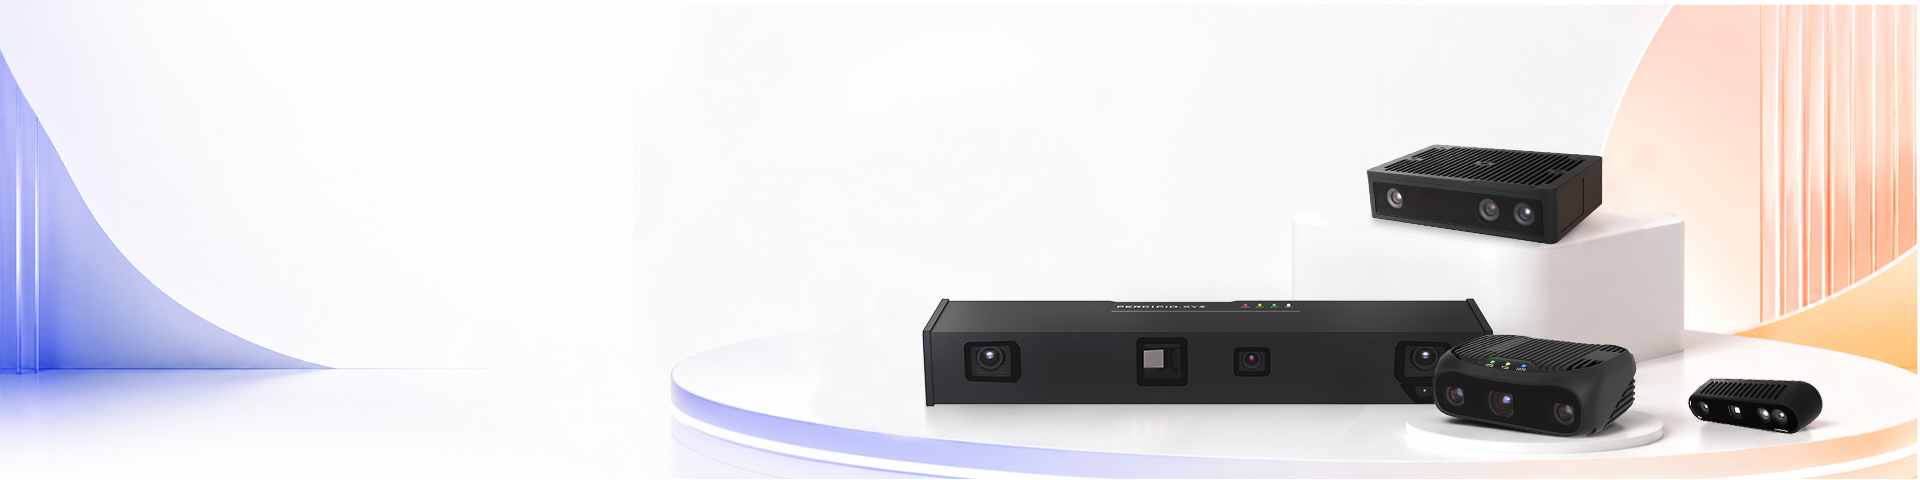
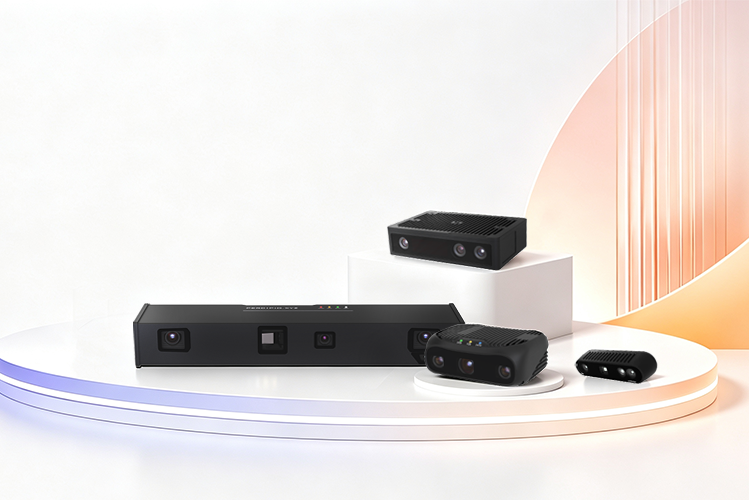
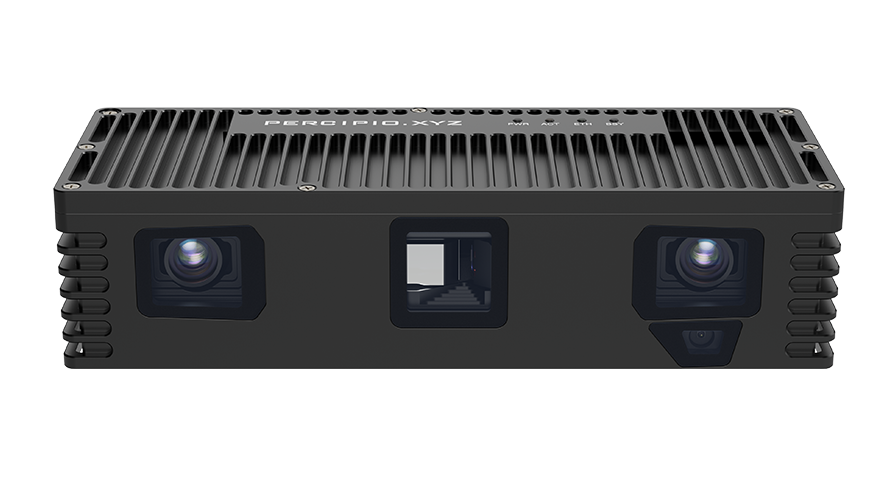
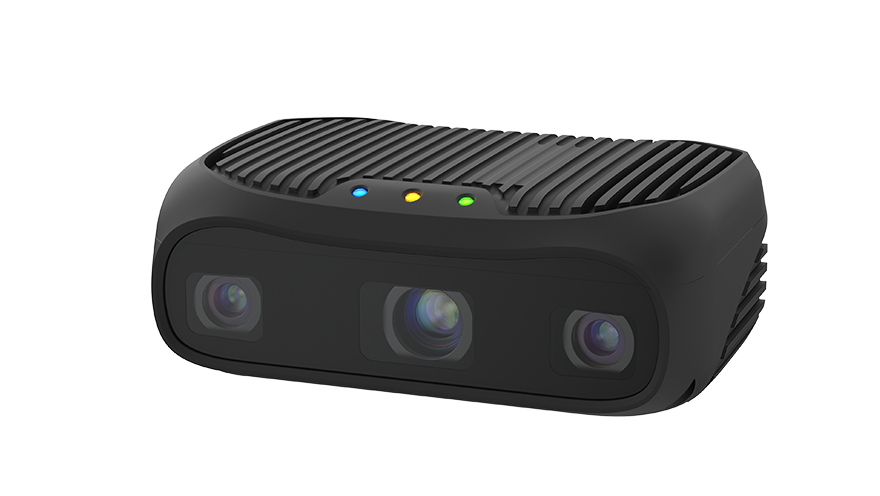
Recommended Cameras